ECCV 2026 | Second Author
Dual-Anchoring: Addressing State Drift in Vision-Language Navigation
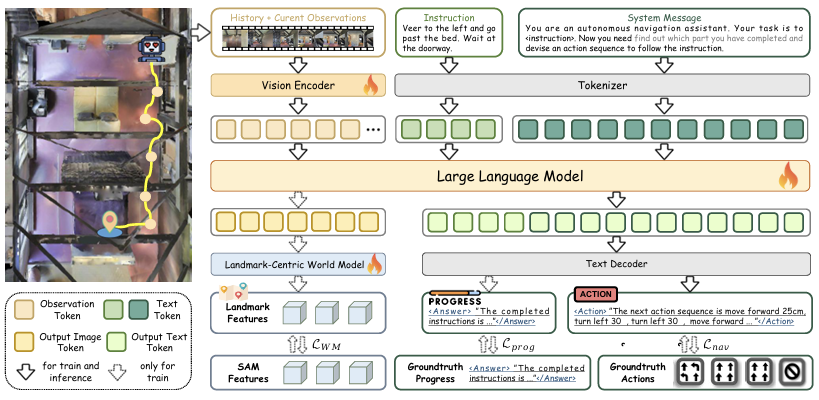
Dual-Anchoring addresses long-horizon state drift in VLN. The framework decomposes the failure into progress drift and memory drift, then explicitly anchors instruction progress and history representations to keep the agent aligned with the true task state.
Abstract Summary
Recent Video-LLM-based VLN systems remain vulnerable to state drift on long trajectories. Dual-Anchoring tackles this through Instruction Progress Anchoring, which explicitly distinguishes completed from remaining sub-goals, and Memory Landmark Anchoring, which uses a landmark-centric world model to preserve distinct representations of visited locations.
This page currently keeps the released framing, architecture, and preprint link. More implementation-specific notes can be added later when the public material is ready.