| Xi Lin I am an M.S. student in Robotics at Johns Hopkins University, working on robot learning and embodied AI. My research centers on world models, VLA systems, and long-horizon embodied decision-making, with a particular interest in physically grounded and generalizable manipulation. I am currently a research intern at Yinwang, working on world-action models for dexterous manipulation with Dr. Zhaowen Li while also studying continual VLA learning at JHU. Previously, I worked on embodied navigation at JD Explore Academy with Dr. Lin Zhao and Prof. Lin Liang, robot motion and control at Xiaomi Robotics, humanoid locomotion at Tsinghua AIR with Prof. Wenchao Ding, and robot dynamics and terradynamics at JHU with Prof. Chen Li. I am applying for Fall 2027 Ph.D. programs and am open to on-site research opportunities from late August 2026 through Spring 2027. |
ResearchMy research focuses on model-side robot learning for generalizable manipulation. I am interested in how robots can build physically meaningful predictions, retain reusable capabilities from experience, and use them for coherent decision-making over long horizons. More broadly, I study embodied coherence: how prediction, learned capability, and executed behavior can remain grounded in the same physical change.
Earlier work in humanoid locomotion, whole-body control, and robot dynamics provides the systems background for this research. |
Publications |
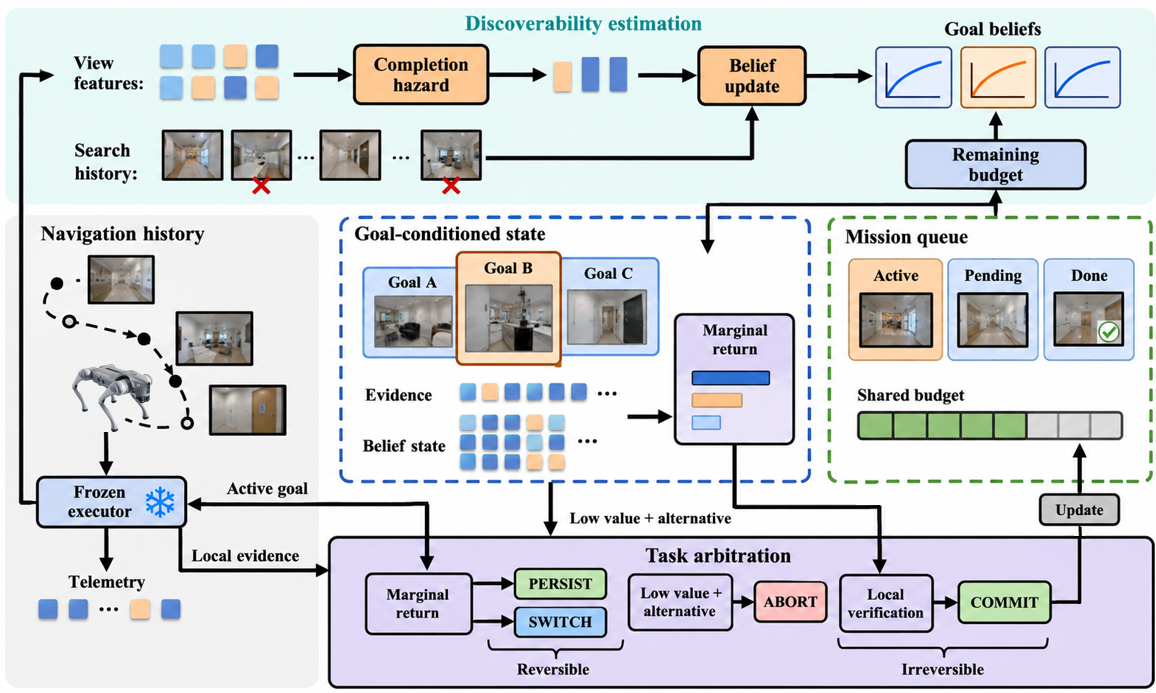 | BAT-Nav: Belief-Based Arbitration and Termination via Remaining Discoverability in Multi-Goal Semantic Navigation Xi Lin, Kangyi Wu, Jiayi Li, Jiaqiao Tang, Qingrong He, and Lin Zhao RAL 2026 | Under Review | First Author project page / arXiv A training-free online goal arbitrator above a frozen navigation executor, estimating remaining discoverability and using marginal return to regulate Persist, Switch, Abort, and Commit decisions under a shared action budget. |
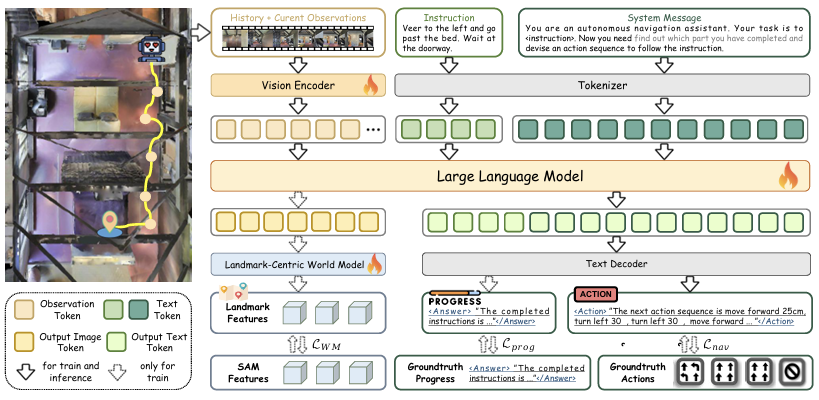 | Dual-Anchoring: Addressing State Drift in Vision-Language Navigation Kangyi Wu, Xi Lin, Pengna Li, Kailin Lyu, Lin Zhao, Qingrong He, Jinjun Wang, and Jianyi Liu ECCV 2026 | Second Author project page / arXiv A dual-anchoring framework for long-horizon VLN that explicitly addresses progress drift and memory drift through instruction-progress anchoring and landmark-centric world-model supervision. |
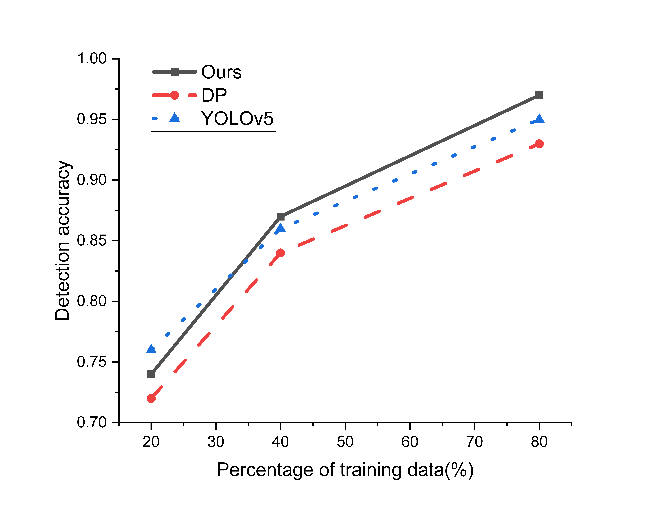 | Research on Object Detection of Robotic Based on Convolutional Neural Network Xi Lin, Yuge Chen, Donglai Liu IEEE IPIC 2023 | First Author project page An earlier competition-oriented project that combined YOLOv5 perception with VINS-Fusion for UAV-style visual navigation and target-aware motion. |